01 / OVERVIEW
Context & problem
An independent robotics effort exploring autonomous systems through perception, localization, sensor integration, and mission-level software. The work spans software prototypes and hardware design exploration rather than one finished, fully integrated flying system.
Autonomy only works when perception, localization, control, and mission logic stay coordinated under real-time constraints. Translating algorithms into a physical platform also introduces hardware and communication boundaries that are absent from offline experiments.
02 / SYSTEM ARCHITECTURE
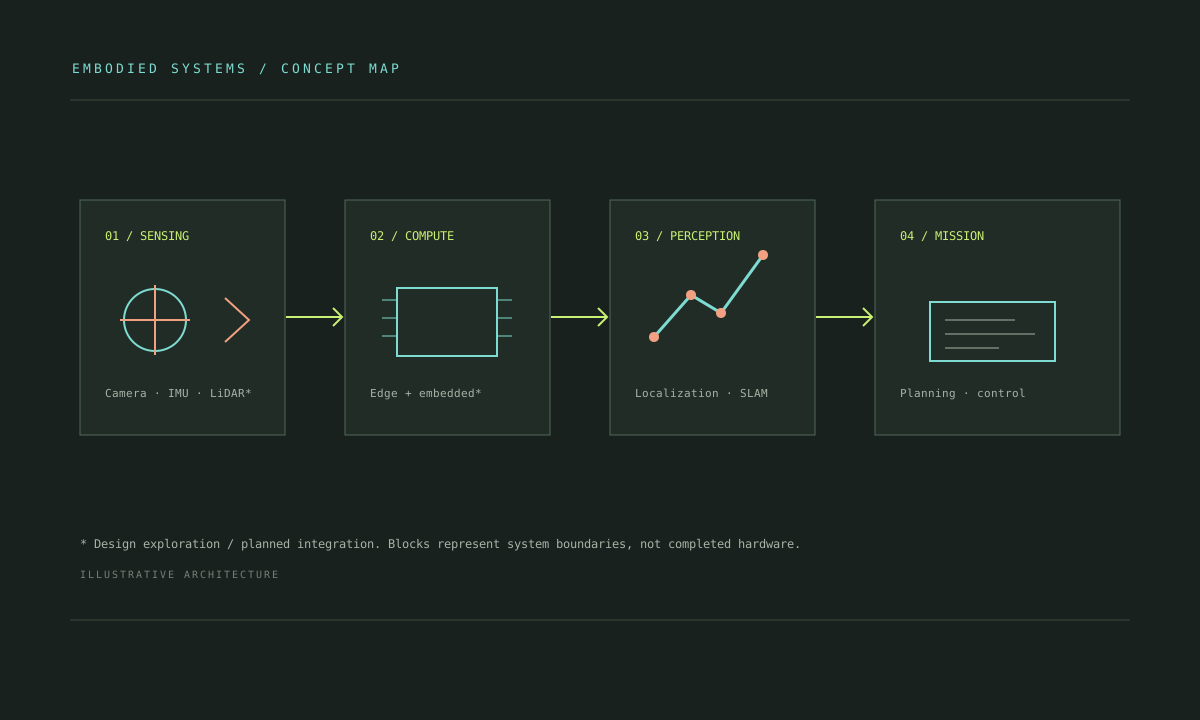
How the pieces connect.
Architecture and hardware callouts are illustrative. Design targets and planned integrations are labeled separately from implemented prototype work.
03 / INDIVIDUAL CONTRIBUTION
What I worked on.
- Developed drone and robotics prototypes spanning autonomous perception, localization, SLAM, and mission-level software.
- Explored controls and embodied-autonomy workflows for systems that perceive and operate in physical environments.
- Worked through system architecture and sensor integration considerations across onboard compute and embedded components.
04 / IMPLEMENTATION
Engineering details.
Autonomy only works when perception, localization, control, and mission logic stay coordinated under real-time constraints. Translating algorithms into a physical platform also introduces hardware and communication boundaries that are absent from offline experiments.
- Prototype software covers perception, localization, and autonomy workflows.
- Hardware options under design exploration include Jetson Orin Nano, LiDAR and IMU sensing, and Raspberry Pi Pico microcontrollers.
- SPI links with Rust-based components, 15-inch propeller designs, and a target thrust-to-weight ratio near 2.5:1 are design concepts, not claims of a completed integrated aircraft.
05 / RESULTS & VALIDATION
What the work supports.
- Built prototype components across perception, localization, and mission software.
- Current work is exploratory; no completed flight-performance benchmark is claimed.
Validation details are limited to evidence stated in the resume; no unreported datasets, accuracy claims, or benchmark comparisons are added.
MORE WORK
Browse all project case studies GitHub profile