01 / OVERVIEW
Context & problem
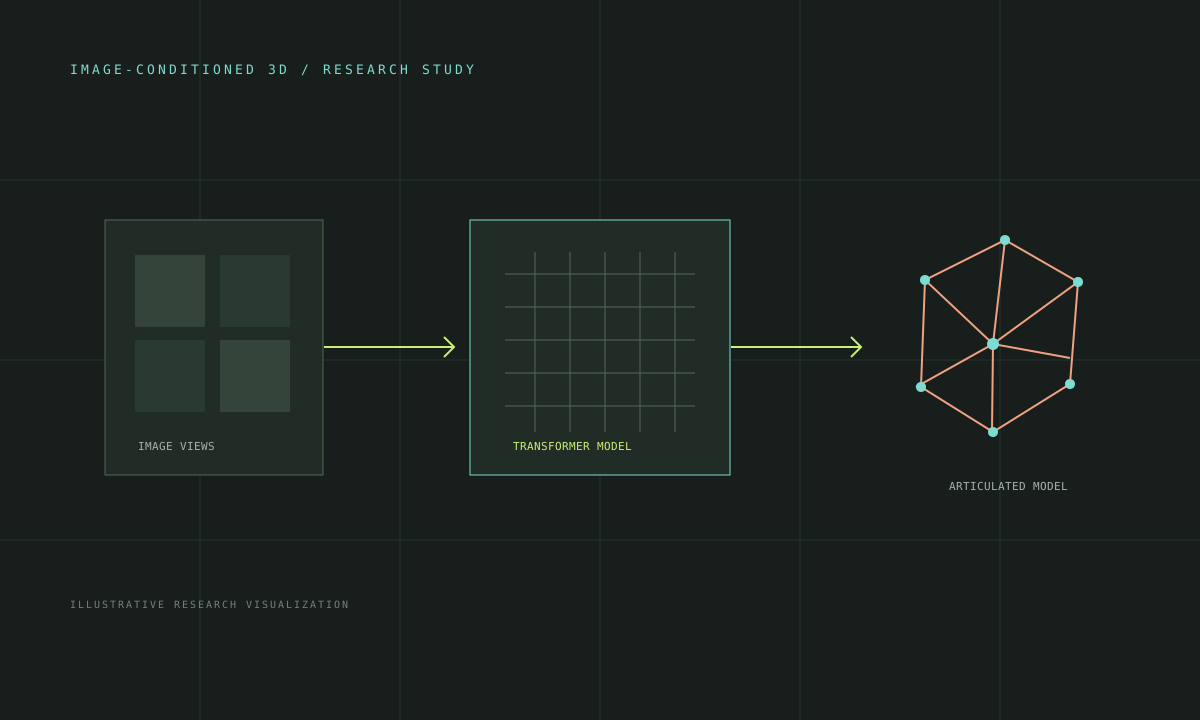
As a Research Aide at the ASU Logos Lab, developed Python/PyTorch transformer models for 3D reconstruction and articulated physical models. The research aims to help robots interact physically with digital twins reconstructed from images.
A useful digital twin needs more than a plausible static shape: it must represent articulated structure in a way that can support downstream physical interaction.
02 / SYSTEM ARCHITECTURE
How the pieces connect.
03 / INDIVIDUAL CONTRIBUTION
What I worked on.
- Developed transformer-based research models in Python and PyTorch.
- Worked on 3D reconstruction and articulated physical-model representations.
- Connected image-based reconstruction research to robotics interaction goals.
04 / IMPLEMENTATION
Engineering details.
A useful digital twin needs more than a plausible static shape: it must represent articulated structure in a way that can support downstream physical interaction.
- Research focused on transformer architectures and image-conditioned 3D representations.
- Experiments were conducted as university research, not a commercially deployed system.
05 / RESULTS & VALIDATION
What the work supports.
- Developed research models and experimentation workflows; no publication or benchmark is claimed.
Validation details are limited to evidence stated in the resume; no unreported datasets, accuracy claims, or benchmark comparisons are added.
MORE WORK
Browse all project case studies GitHub profile